 Illustration
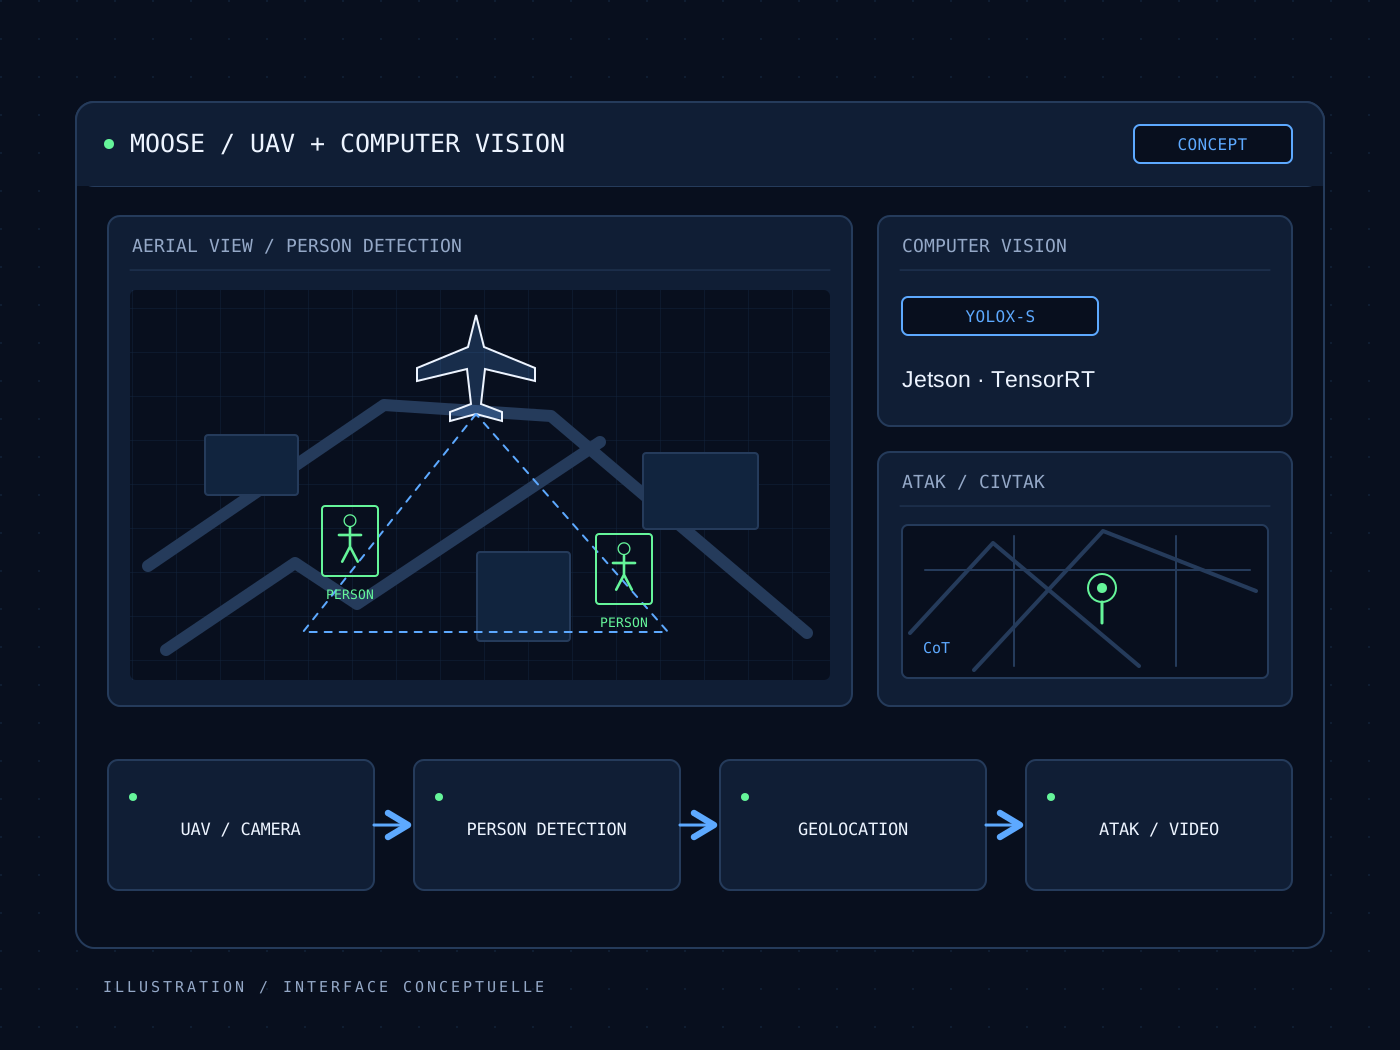
MOOSE
Aerial person detection. Computer vision on a fixed-wing UAV, connected to ATAK.
Explore the projectRobotics / Embedded systems
Traffic-sign recognition, a Raspberry Pi and an ultrasonic sensor bring perception into motion.
01 / The challenge
Connect a trained image classifier with the timing and physical constraints of a moving platform.
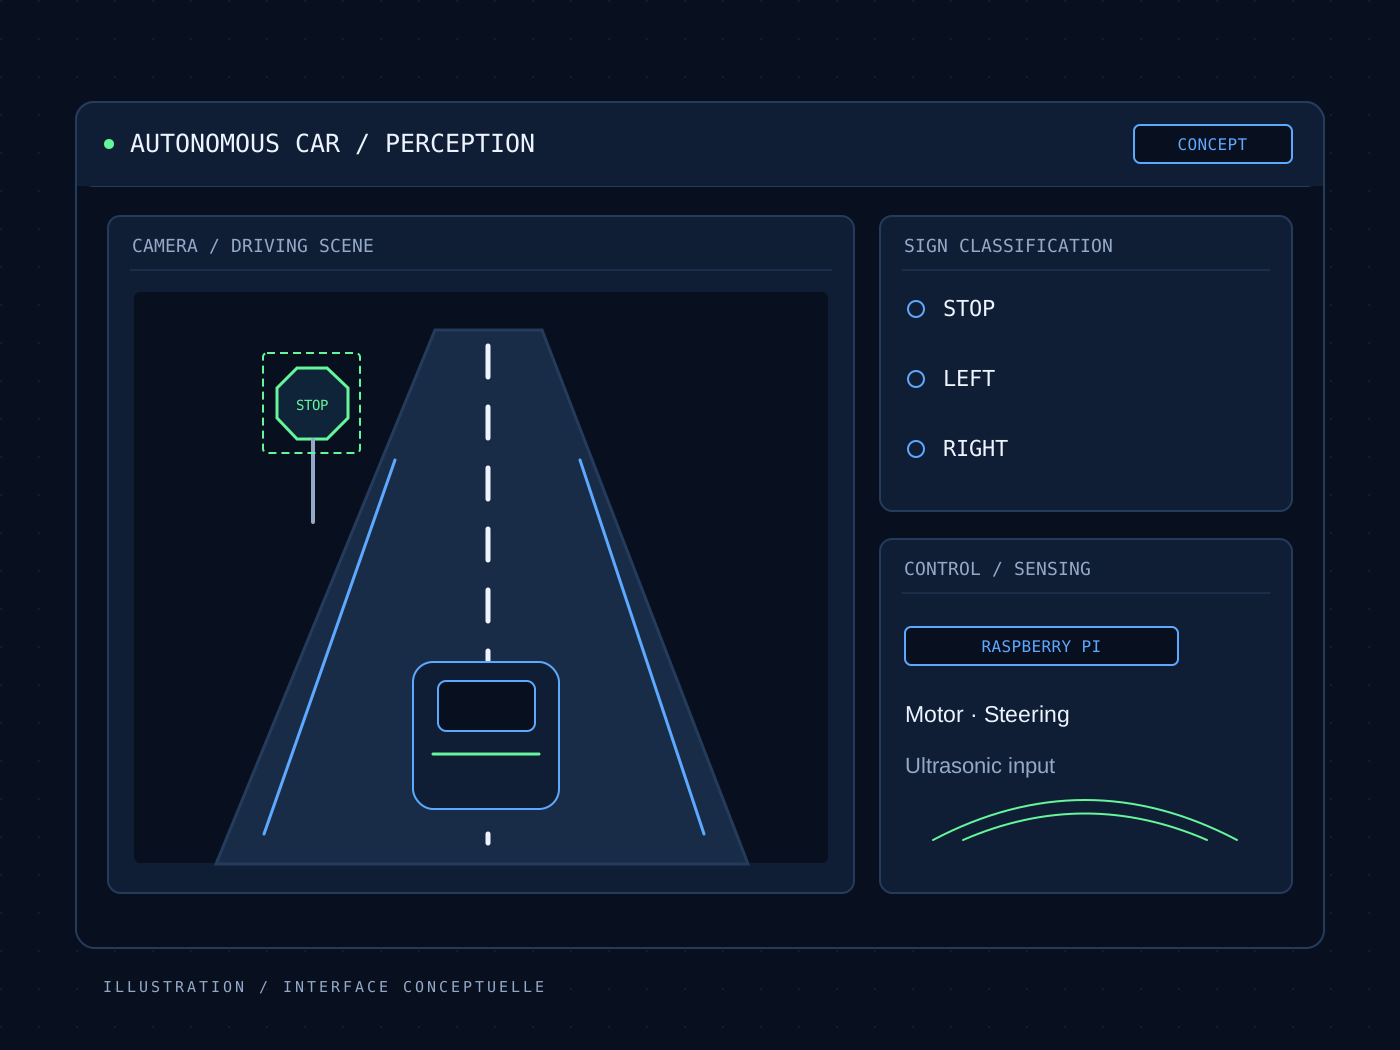
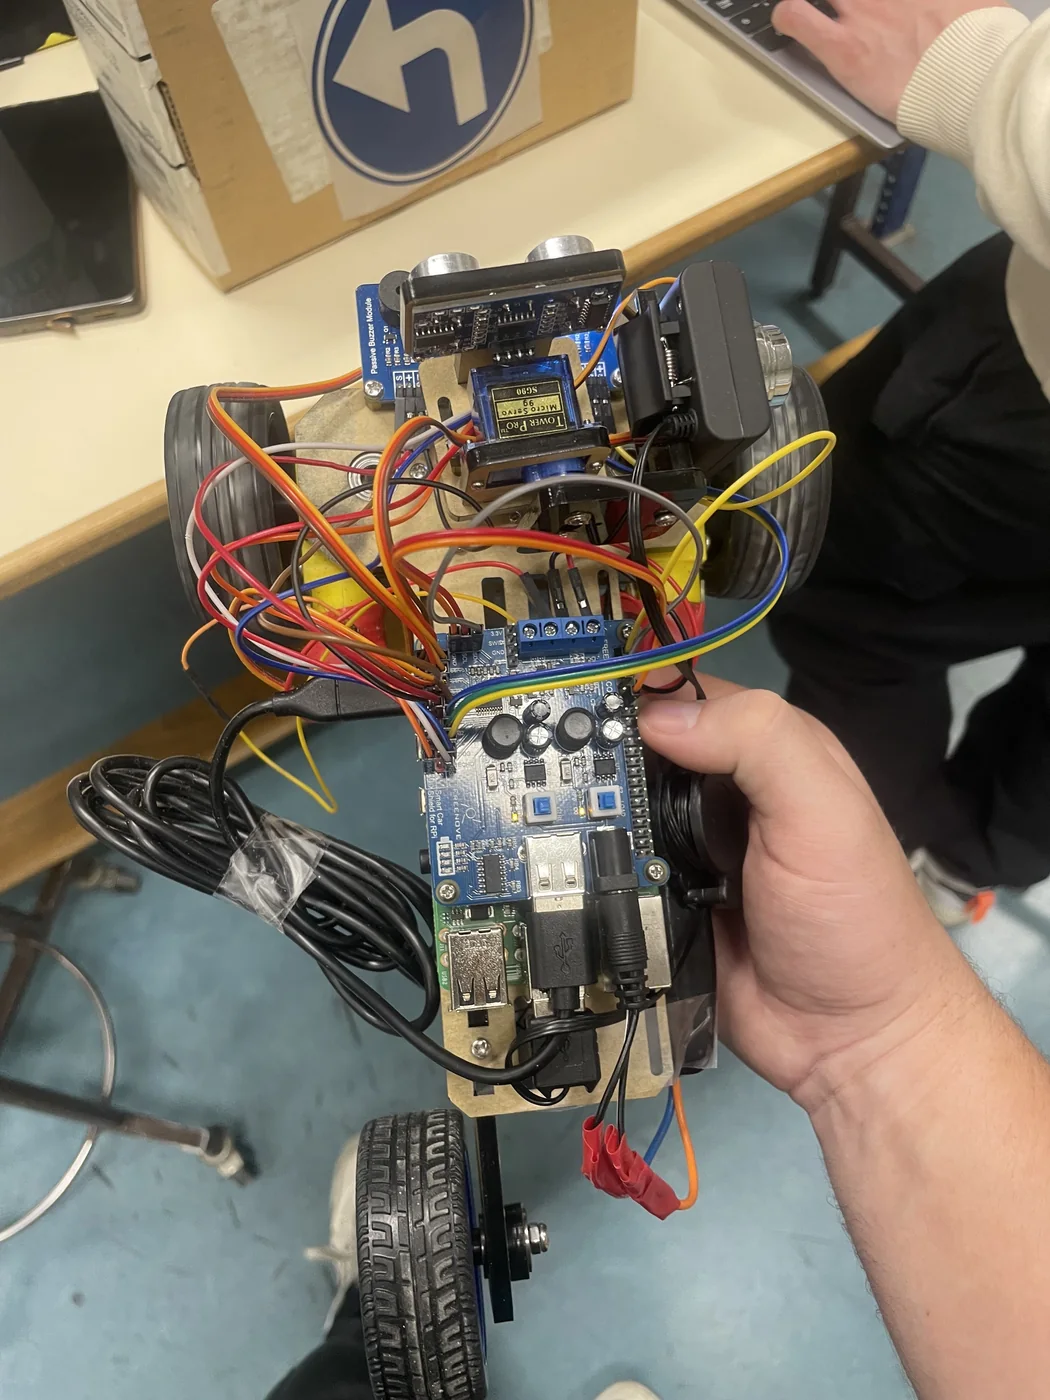
An educational robotic car links a camera-equipped Raspberry Pi to a Flask inference server. A CNN classifies stop, left and right signs, and the client translates the returned decision into motor and steering commands. Ultrasonic sensing adds obstacle detection.
02 / The approach
Train a CNN to distinguish the three traffic-sign classes.
Capture images on the Raspberry Pi, send them to a Flask API and apply the returned movement command.
Read ultrasonic distance and integrate an obstacle-triggered stop with motor and steering control.
03 / Outcomes
04 / Scope & next steps
Field notes / Visual documentation
Continue exploring